Zhiling Chen
陈智灵, Ph.D.
PhD candidate in Mechanical Engineering at University of Connecticut
About
Hi, I'm Zhiling Chen👋, a third-year Mechanical Engineering PhD student at  University of Connecticut and a research assistant at Intelligent Systems and Control Laboratory (ISCL), , where I am advised by Dr. Farhad Imani and Dr. Ruimin Chen. My PhD journey has taken me through three different research directions in three years. About two and a half years in, I found my way into robotics, and it quickly became the field I want to pursue long term. My vision is to build scalable, general-purpose intelligent robots that can learn, adapt, and operate reliably in the real world.
🔬 Research Interests: Agentic Robotics, Embodied Inspection, Robotic Manufacturing.
Latest News
A New Friend Joins Our Lab: Unitree H2
A New Friend Joins Our Lab: Unitree H2
🤖 We welcomed a new friend to our lab, the Unitree H2!
Two Papers Accepted to IROS 2026 (first-authored SenseHD and ScanBot)
Two Papers Accepted to IROS 2026 (first-authored SenseHD and ScanBot)
📄 Got two first-authored papers accepted to IROS 2026. Thanks to all my collaboators!
Paper Accepted (first-authored MoXpert, Pattern Recognition)
Paper Accepted (first-authored MoXpert, Pattern Recognition)
📄 Got one first-authored paper accepted to Pattern Recognition. Thanks to all my collaborators!
Paper Accepted (first-authored FedDHD, Internet of Things)
Paper Accepted (first-authored FedDHD, Internet of Things)
📄 Got one first-authored paper accepted to Internet of Things. Thanks to all my collaborators!
Paper Accepted (FedHDPrivacy, Computers and Electrical Engineering)
Paper Accepted (FedHDPrivacy, Computers and Electrical Engineering)
📘 Got one paper accepted to Computers and Electrical Engineering. Congratulations to Fardin Jalil Piran!
Check out my latest work
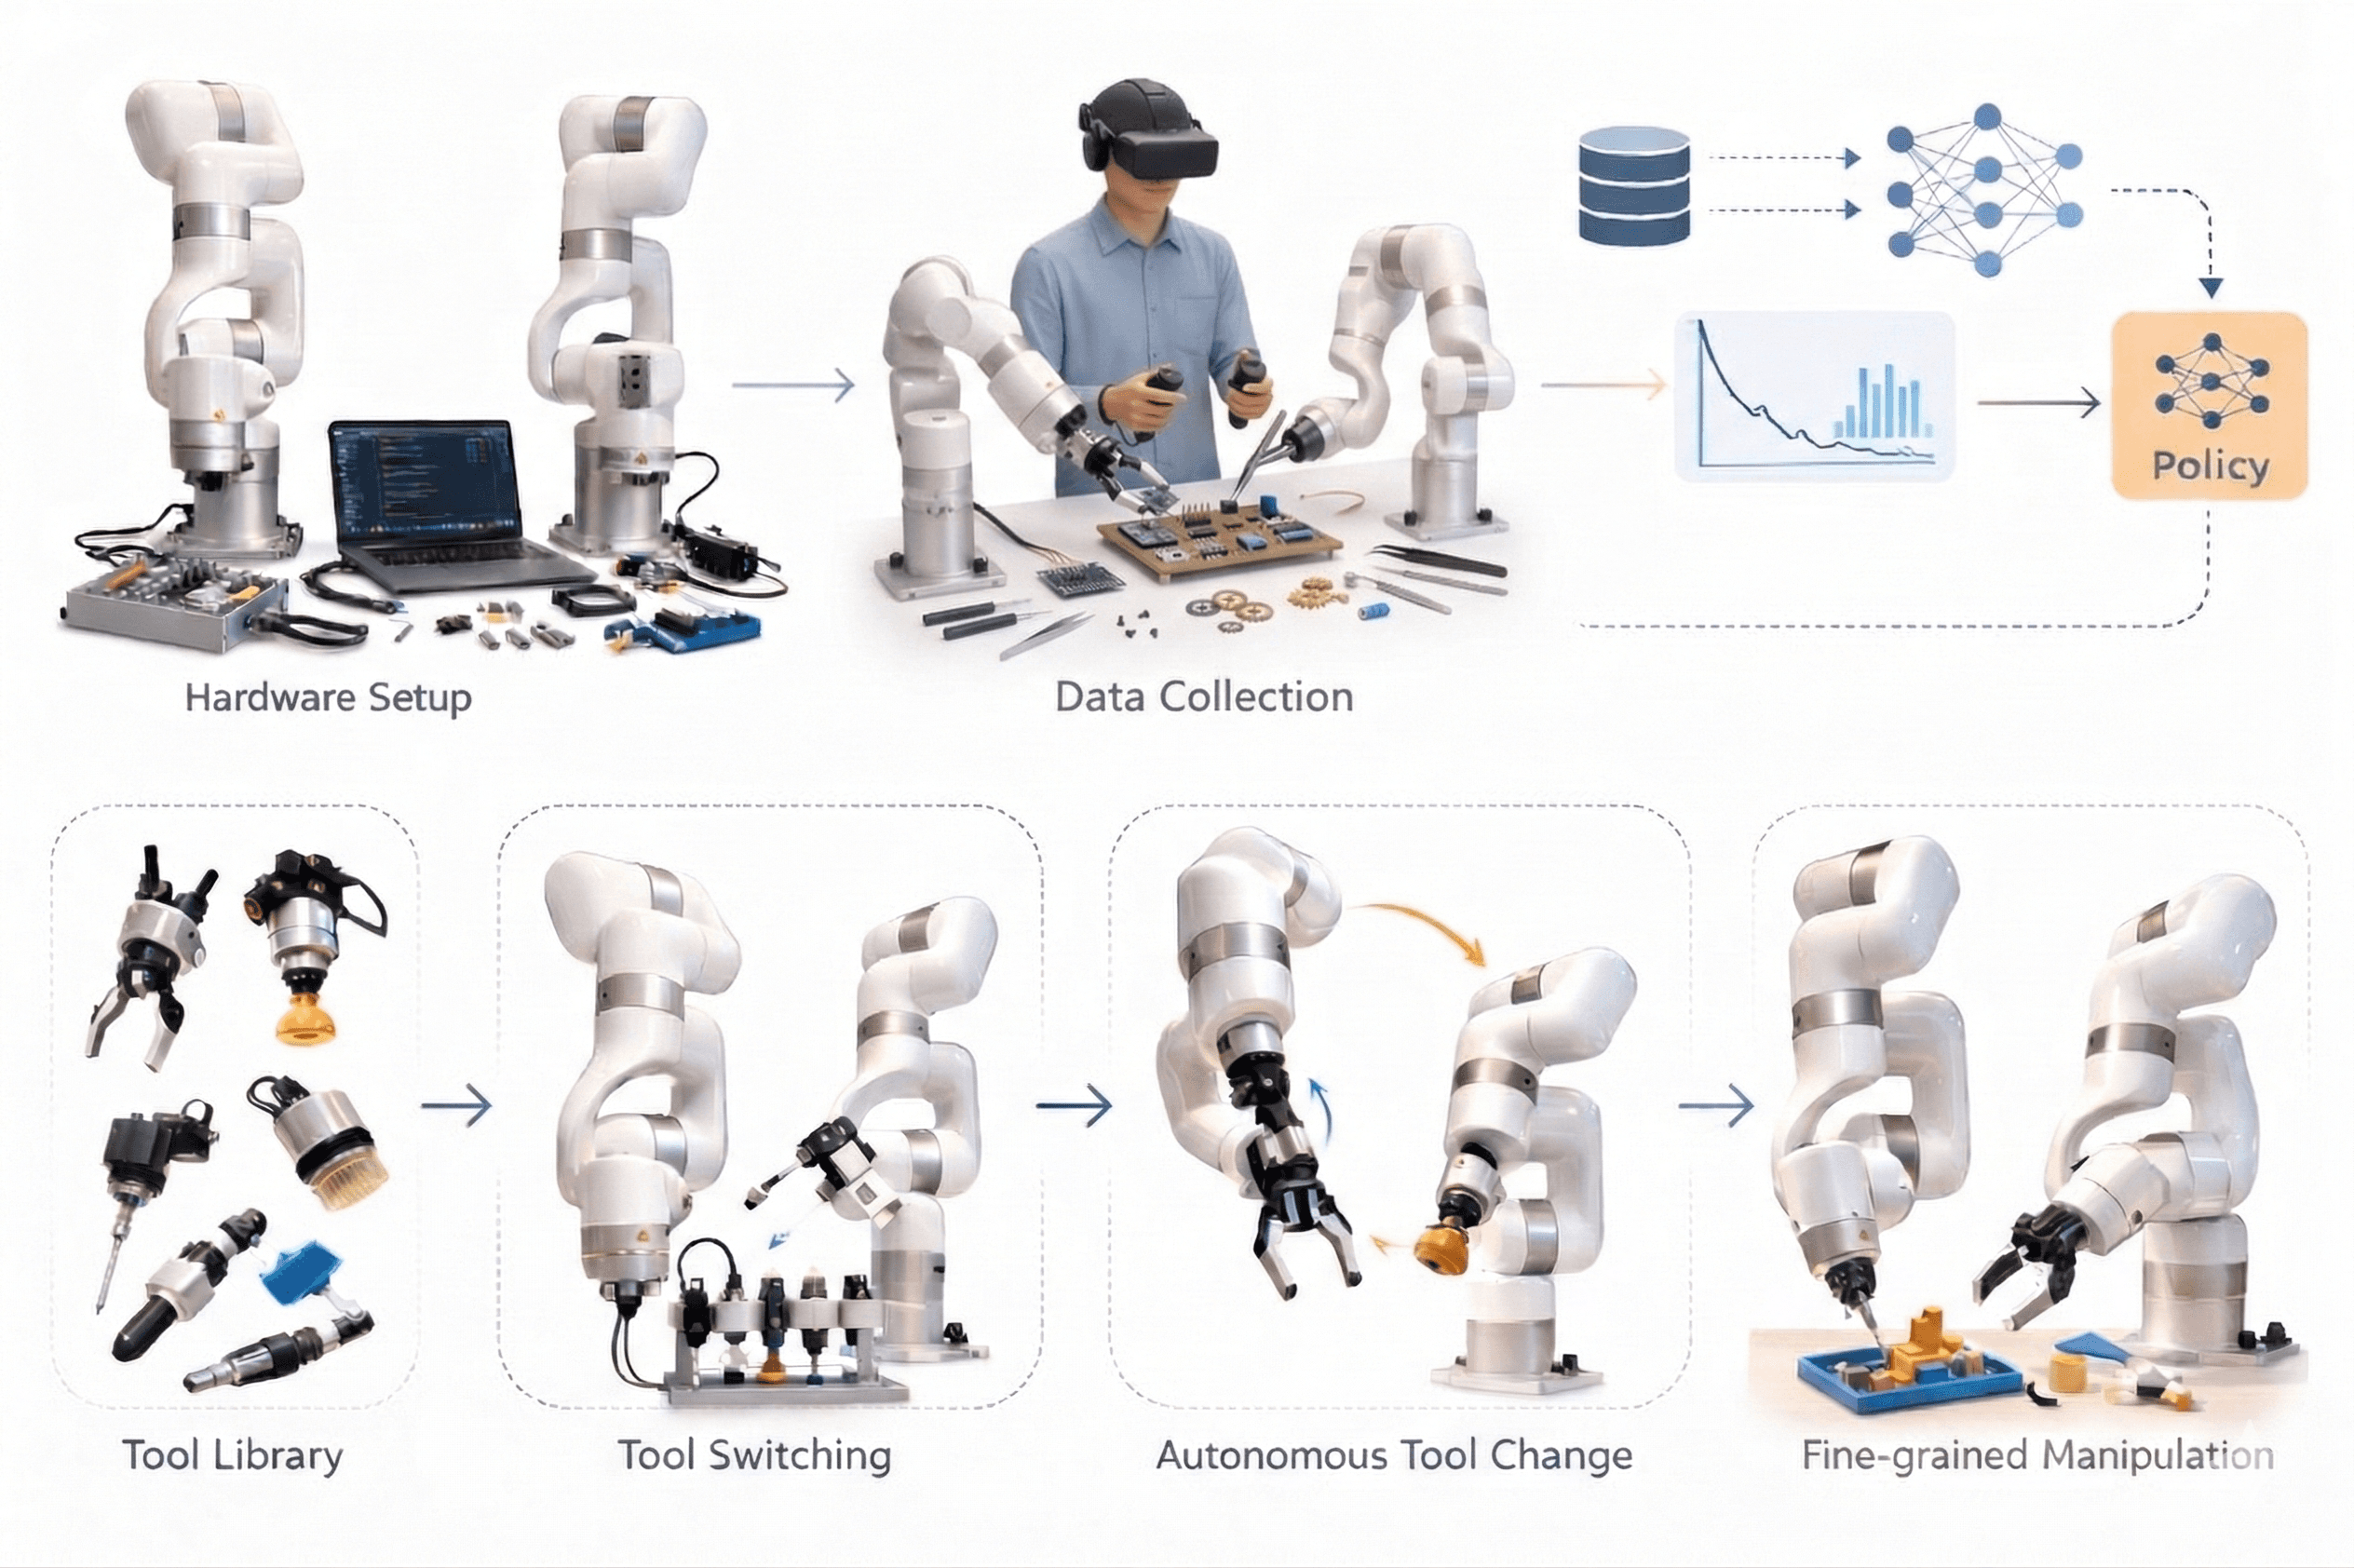
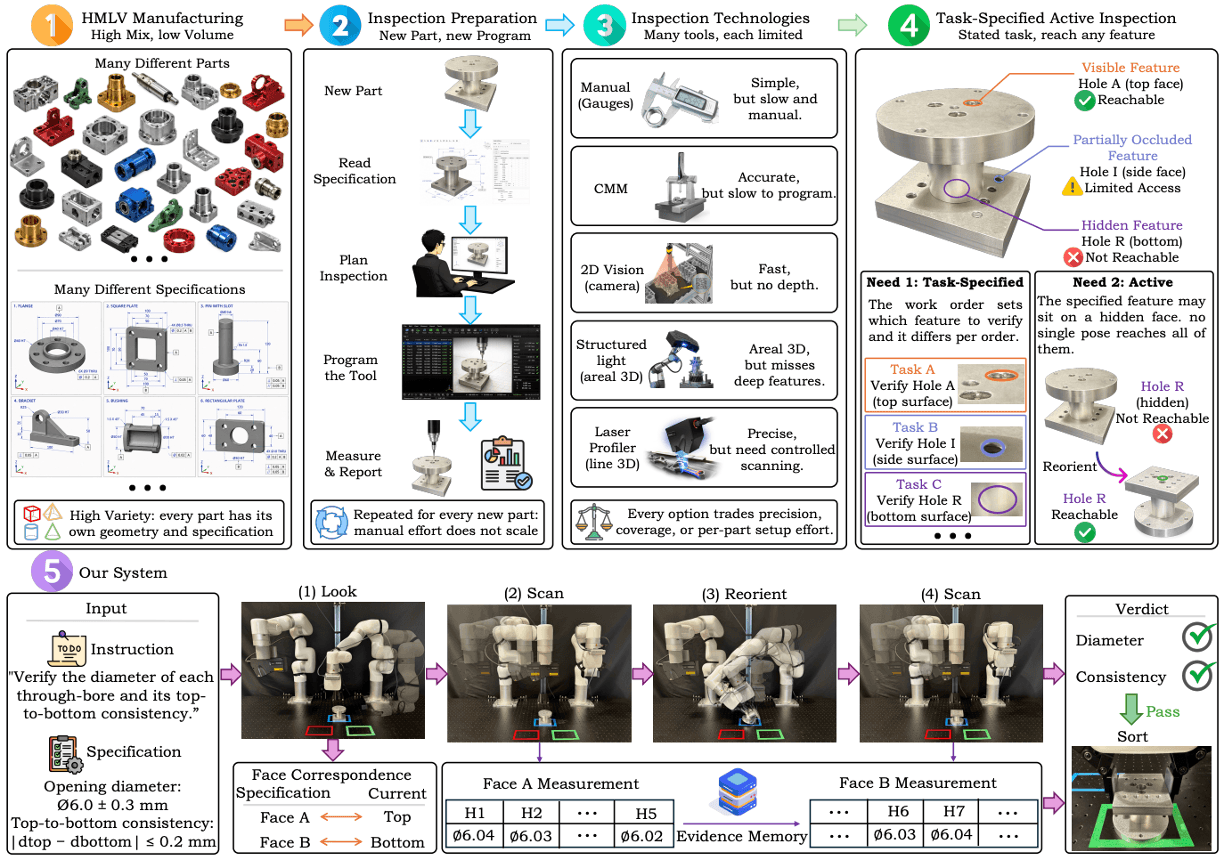
Task-Specified Active Metrological Inspection with Measurement-Steered VLA Manipulation and Deterministic Evidence Gating
Task-Specified Active Metrological Inspection with Measurement-Steered VLA Manipulation and Deterministic Evidence Gating
An agentic framework for autonomous robotic inspection.
Authors: Zhiling Chen, Jingzhan Ge, Ruimin Chen, Matthew P. Castanier, David Gorsich, Farhad Imani
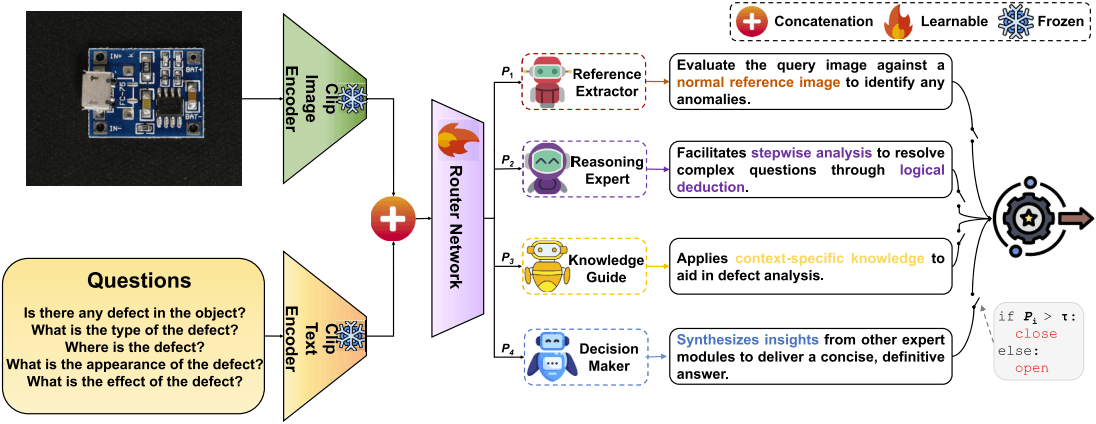
A multi-expert framework for enhancing multimodal large language models in industrial anomaly detection
A multi-expert framework for enhancing multimodal large language models in industrial anomaly detection
A multi expert framework named MoXpert to enhance the capabilities of multimodal large language models (MLLMs) in indusrial anomaly detection.
Authors: Zhiling Chen, Farhad Imani
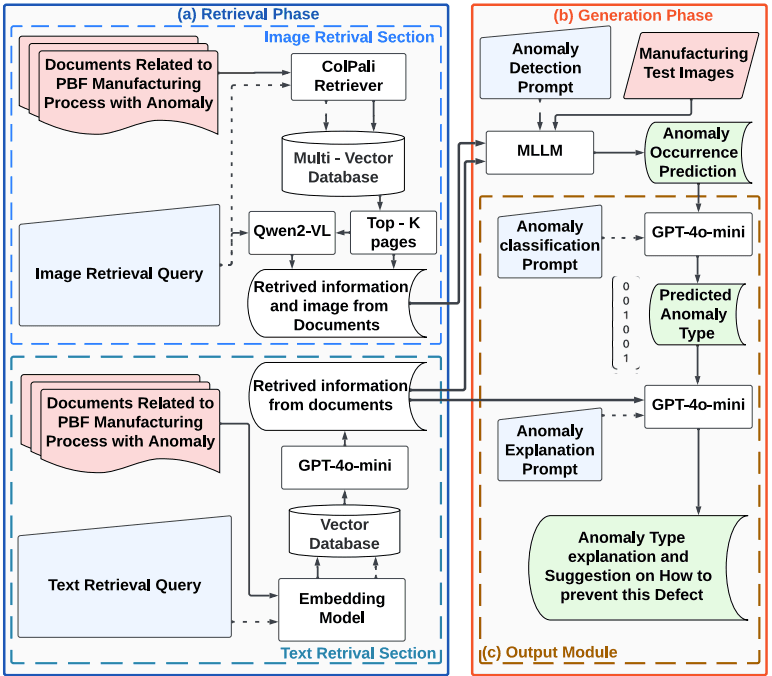
Zero-Shot Anomaly Detection in Laser Powder Bed Fusion Using Multimodal RAG and Large Language Models
Zero-Shot Anomaly Detection in Laser Powder Bed Fusion Using Multimodal RAG and Large Language Models
A multimodal RAG framework is proposed to automate anomaly detection in additive manufacturing (AM) without relying on task-specific training data.
Authors: Kiarash Naghavi Khanghah, Zhiling Chen, Lela Romeo, Qian Yang, Rajiv Malhotra, Farhad Imani, Hongyi Xu
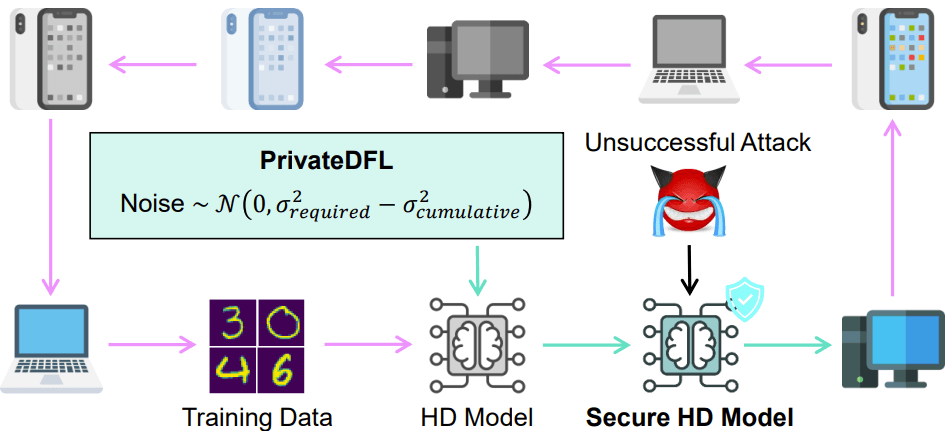
Privacy-preserving decentralized federated learning via explainable adaptive differential privacy
Privacy-preserving decentralized federated learning via explainable adaptive differential privacy
A privacy-accountable and explainable decentralized federated learning framework is introduced by integrating HyperDimensional computing with an explicit differential privacy noise accountant.
Authors: Fardin Jalil Piran, Zhiling Chen, Yang Zhang, Qianyu Zhou, Jiong Tang, Farhad Imani
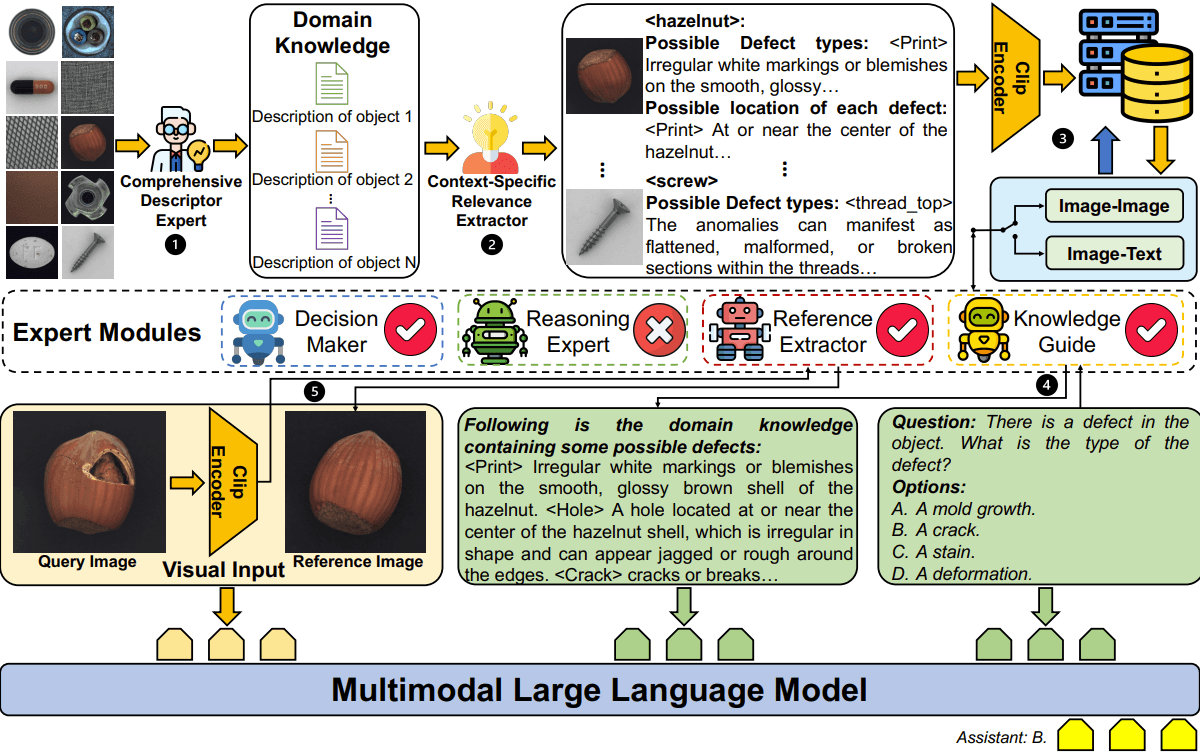
Can multimodal large language models be guided to improve industrial anomaly detection?
Can multimodal large language models be guided to improve industrial anomaly detection?
We propose Echo, a novel multi-expert framework designed to enhance MLLM performance for industrial anomaly detection.
Authors: Zhiling Chen, Hanning Chen, Mohsen Imani, Farhad Imani
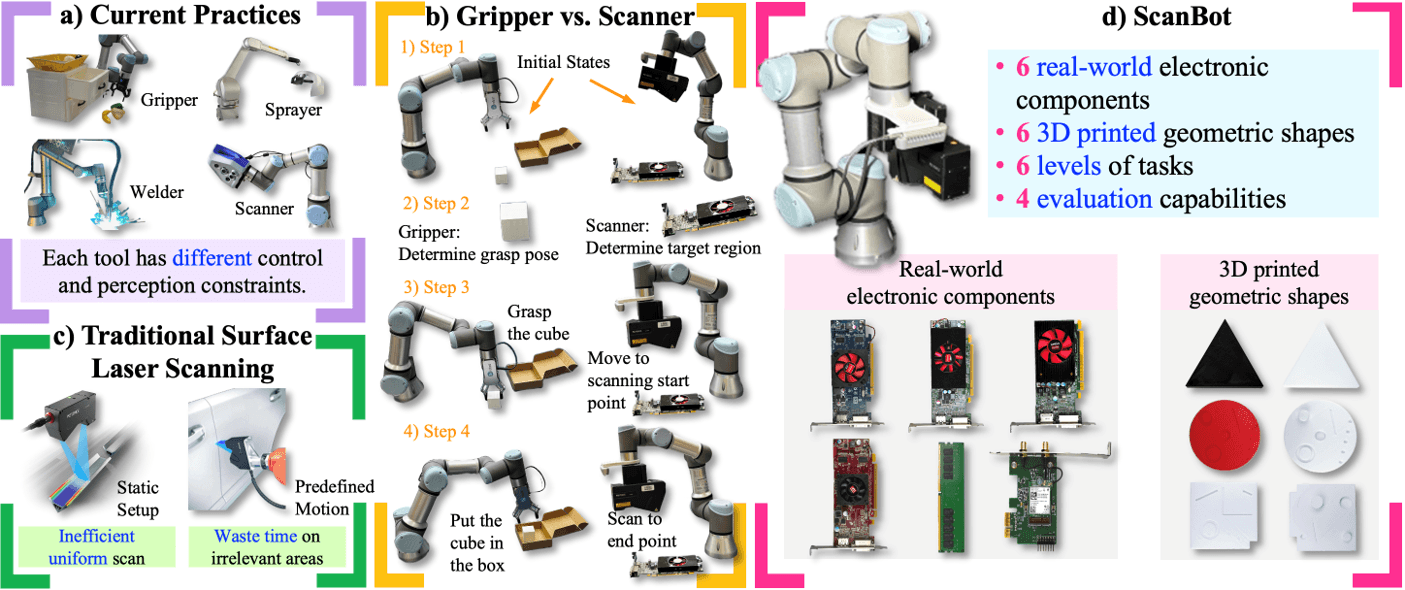
ScanBot: Towards Intelligent Surface Scanning in Embodied Robotic Systems
ScanBot: Towards Intelligent Surface Scanning in Embodied Robotic Systems
We introduce ScanBot, a novel dataset designed for instruction-conditioned, high-precision surface scanning in robotic systems.
Authors: Zhiling Chen, Yang Zhang, Fardin Jalil Piran, Qianyu Zhou, Jiong Tang, Farhad Imani
human · robots · cat
Feier
My Love
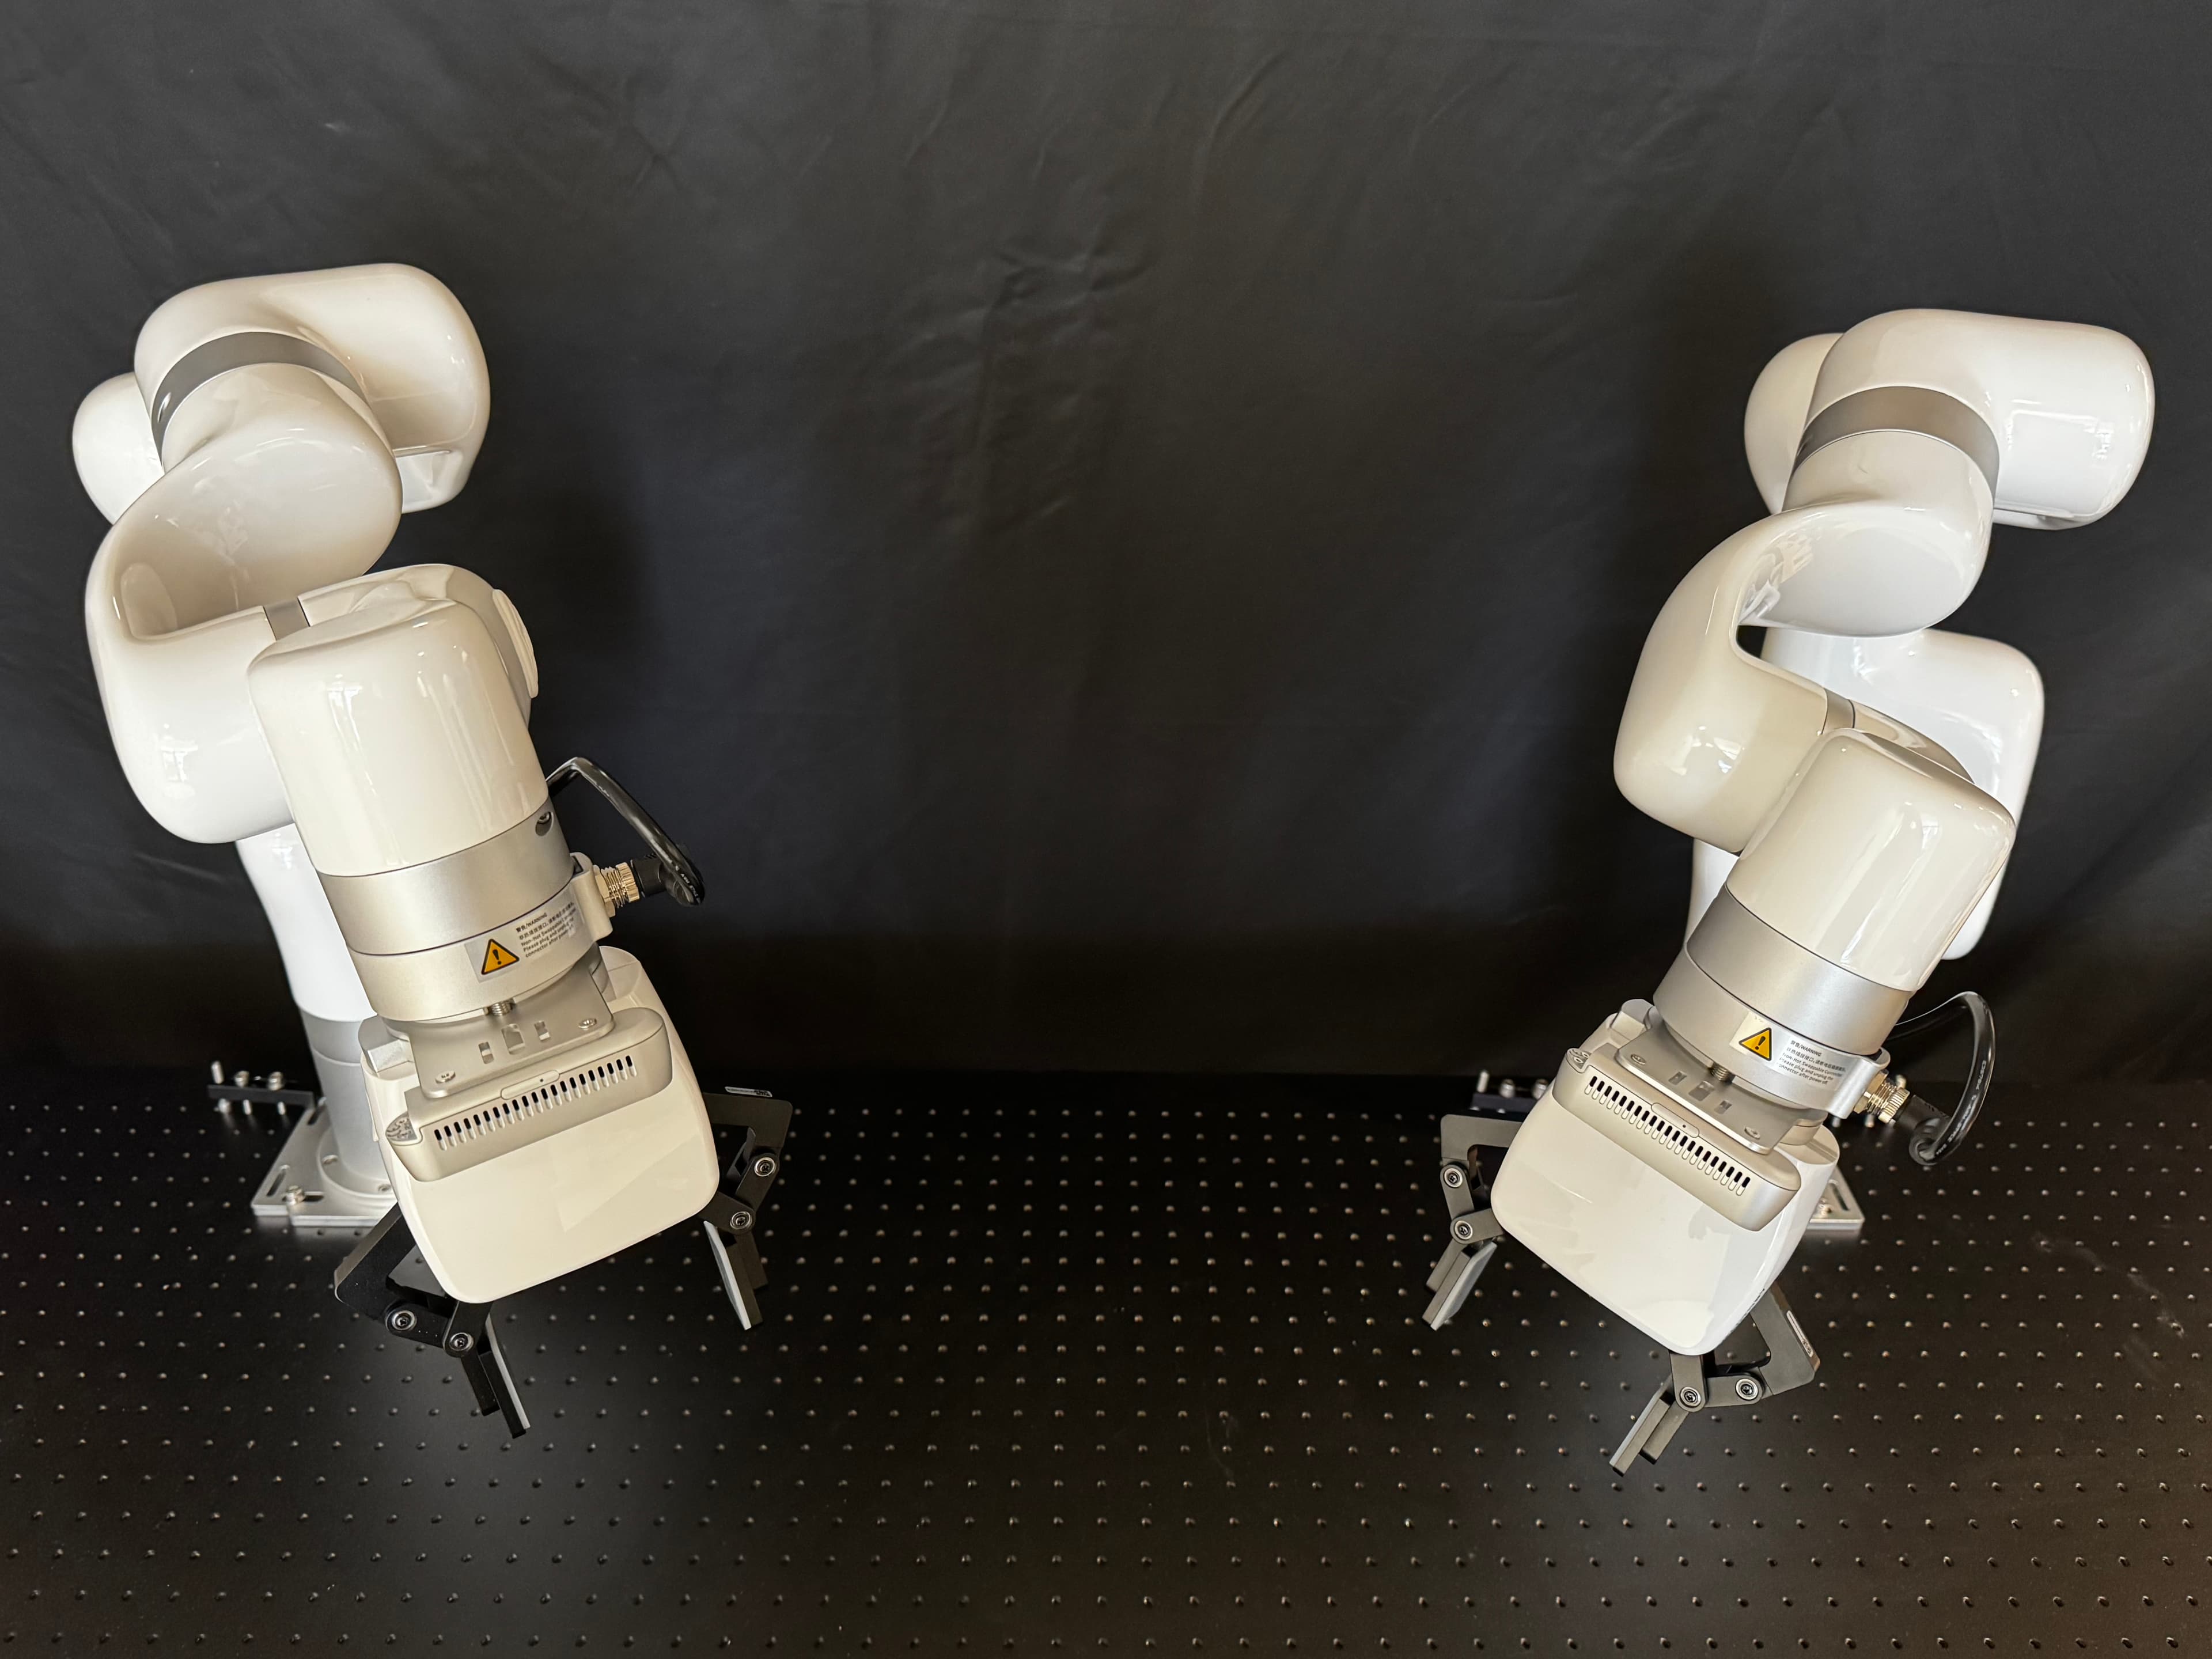
Tom and Jerry
xArm 6
Brandy
British Short Hair
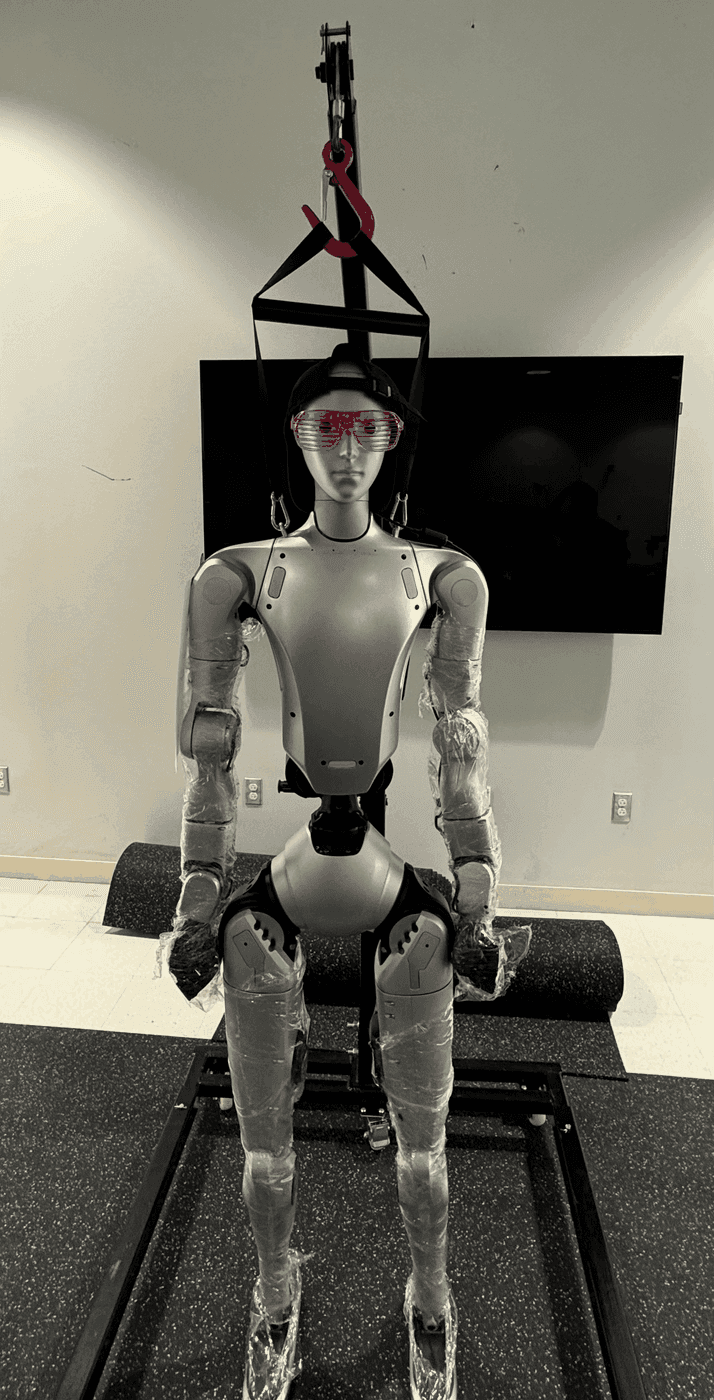
New friend
Unitree H2
Skills
Education
University of Connecticut
Boston University
Waterford Institute of Technology
Nanjing University of Information Science & Technology
Jiangsu Xishan Senior High School
Internship & Work Experience
ISCL Lab, University of Connecticut
Wuxi CHAOTONG Intelligent Research Institute Co., Ltd
Awards & Honors
ASME DFMLC Best Paper Award
Pratt & Whitney Advanced Systems Engineering Travel Fellowship
Academic Services
ME3221: Manufacturing Automation
ME3295: Special Topics in MEM
ME3221: Manufacturing Automation
Get in Touch
Want to chat? Feel free to reach out via email →
- • Ask questions
- • Explore collaboration opportunities